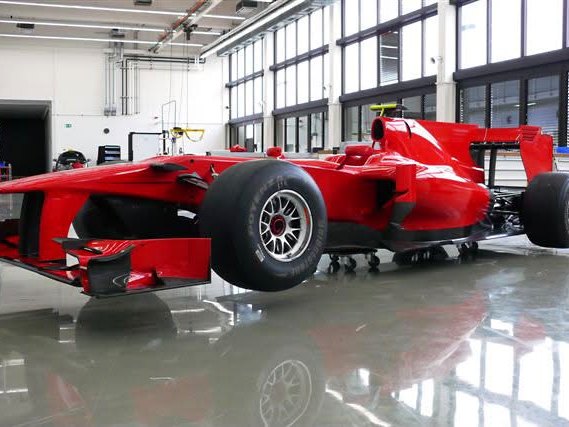
Formula 1
Control code that has to behave identically on every lap — deterministic task timing, calibratable maps and CAN traffic that stays inside its budget.
Embedded softwareOne team writes the software, designs the hardware it runs on, and tests both on our own HIL rigs.
Real-time firmware, Simulink models and FPGA logic, written to ISO 26262 and DO-178C.
02XCP-calibratable platforms, from a prototype board to a production ECU.
03Real-time simulation rigs and automated tests that run before anything ships.
04MIL and autosport wiring harness design, specification and validation.
05The scSVD2 servo valve driver and the scVCU vehicle control unit.
Where our embedded software runs. Every discipline below sets the timing, robustness and diagnostics the code is written to.
Control code that has to behave identically on every lap — deterministic task timing, calibratable maps and CAN traffic that stays inside its budget.
Embedded software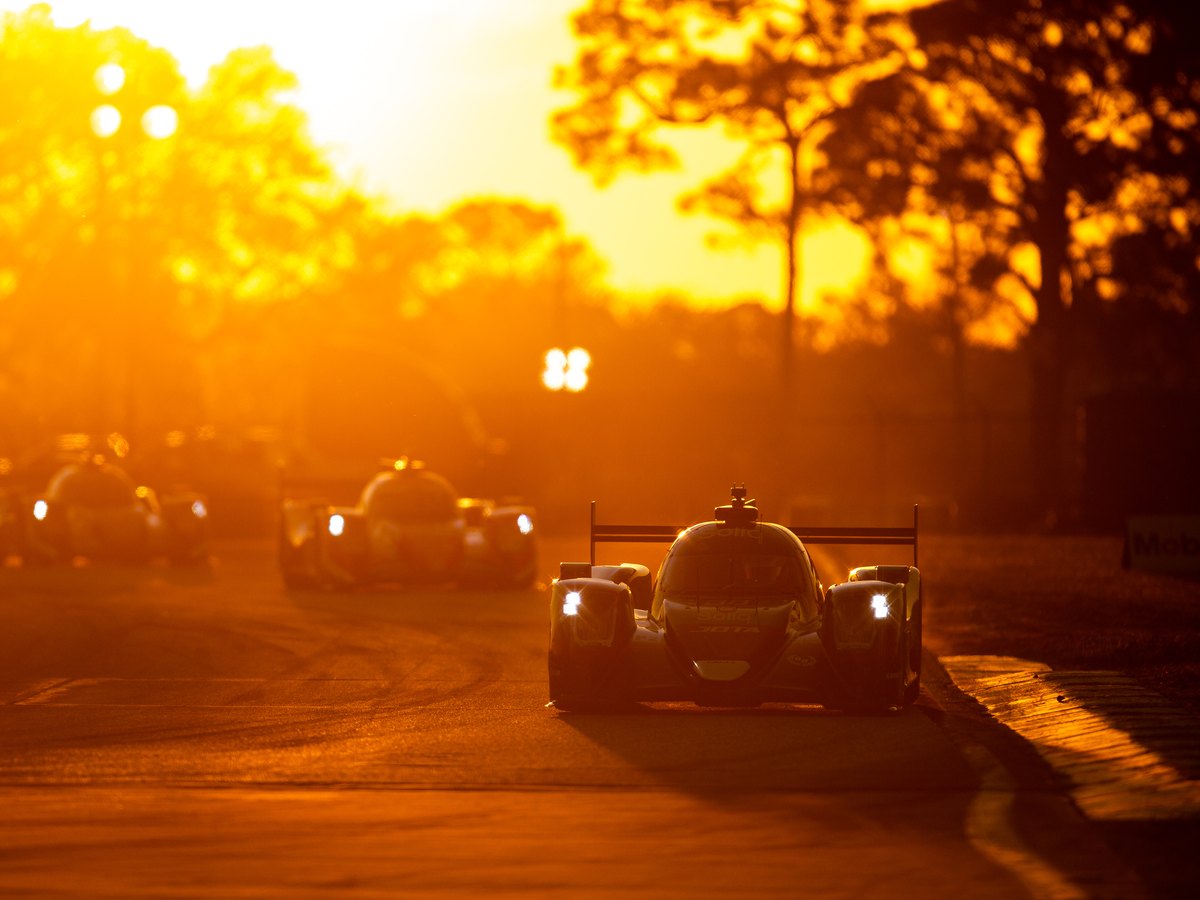
Twenty-four hours without a reset: watchdogs, fault handling and diagnostics written so a problem is visible from the pit wall, not after the flag.
Embedded software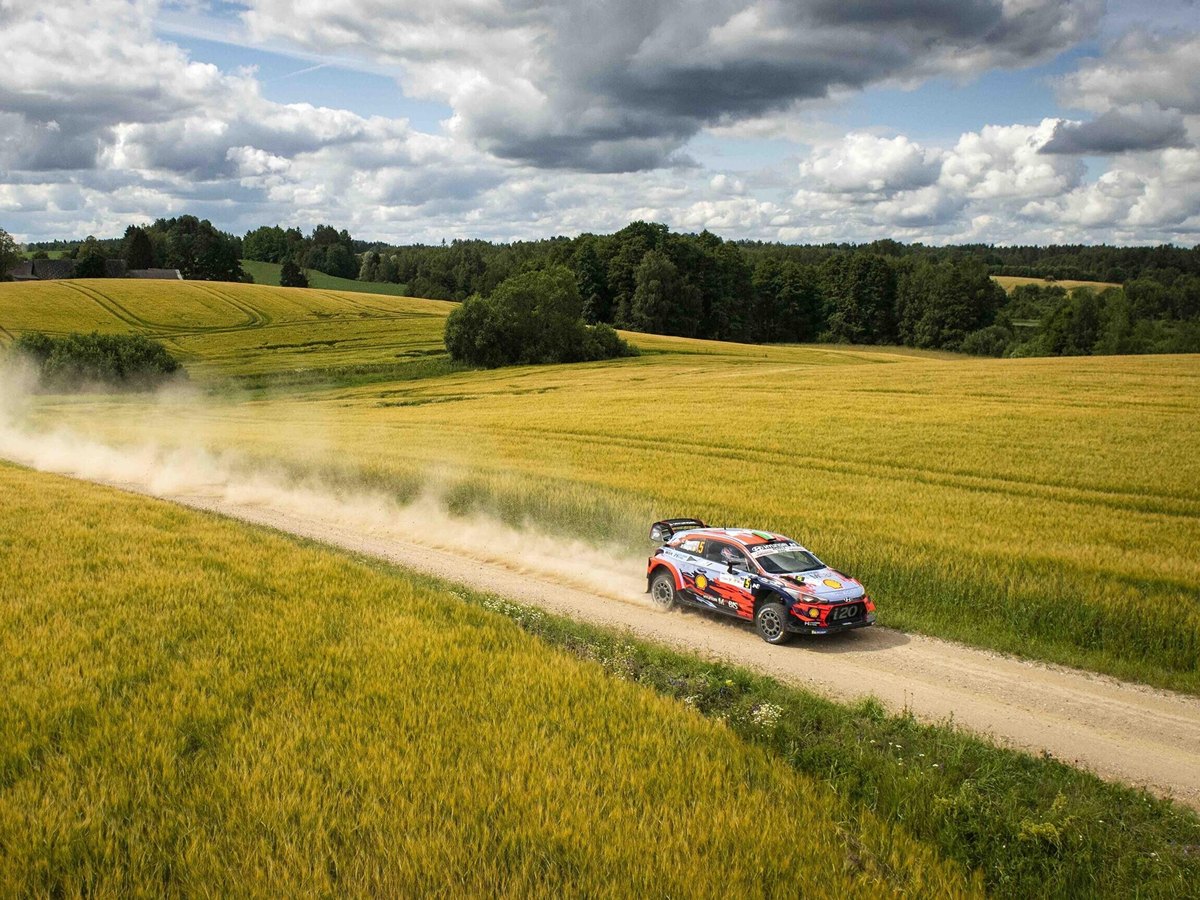
Embedded control built for gravel, heat and vibration — robust I/O handling, resilient logging and configuration that changes between stages.
Embedded software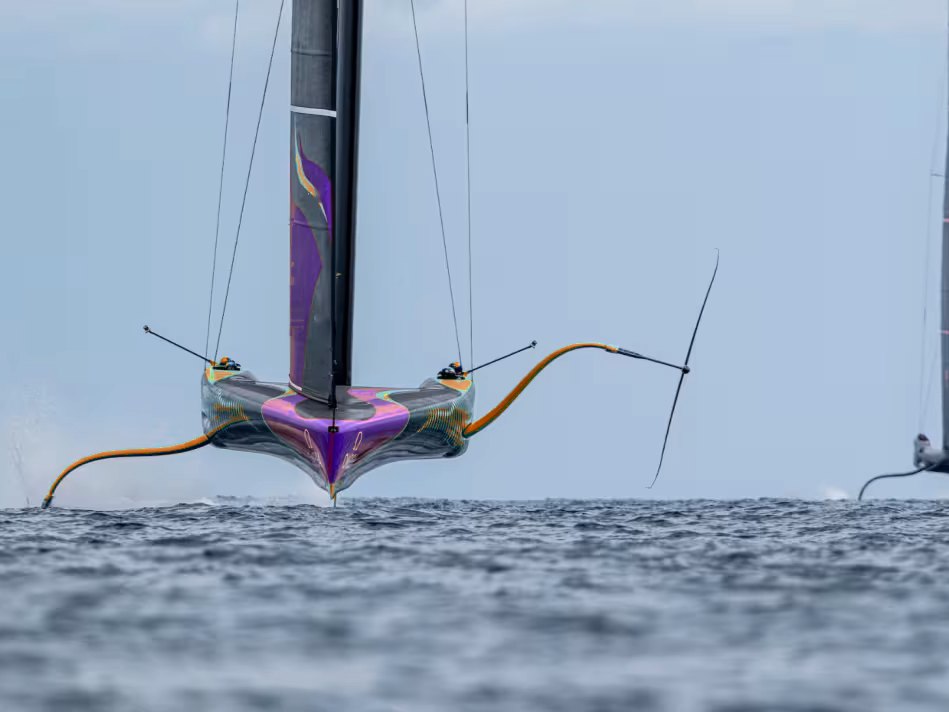
Rig loads, foil position and boat instrumentation fused in real time, so the crew and the shore team read the same numbers.
Embedded softwareControl algorithms modelled in MATLAB/Simulink, specified with the hardware.
Embedded C, FPGA logic and hardware from the same team.
Run on our HIL rigs across operating conditions before delivery.